

NVIDIA and partners present simulation-based robot training for precise manipulation at CoRL
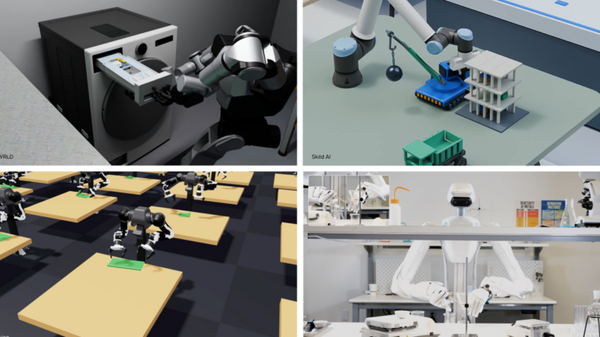
NVIDIA and partners showcased research at the CoRL conference on simulation-based training of robots for fine manipulation tasks – alignment, cable connection, and component assembly – with a shift from locomotion to manipulation.
NVIDIA and its partners presented research at the Conference on Robot Learning (CoRL) focused on training robots for fine manipulation tasks using simulation. These include tasks such as gear alignment, cable connection, and assembly of small components.
According to the source, the focus of research in robot learning is shifting from locomotion (walking, driving, jumping), where simulation has already served as a testing ground, toward more precise object manipulation. The approach combines simulation environments with robot learning methods.
The available description of the event is limited to introductory information about the topic and its inclusion at the CoRL conference. For details, see the source article.
Why it matters
Training in simulation allows robots to practice precise tasks such as assembly or cable connection without the need for extensive real-world data, which is relevant for manufacturing and automation companies following progress in robot learning. However, the sources do not state specific products, performance results, or a timeline for commercial deployment.
Relevant practical impact
What this means
For a business
The shift in research focus from locomotion to fine manipulation in simulations could in the future reduce the cost of training robots for assembly and manufacturing tasks, but the sources do not describe a specific product or commercial availability.
DevelopmentCheck the original
Event sources
only one source so far · 1 publisher, 0 independent. We count feeds from the same owner only once.